- New
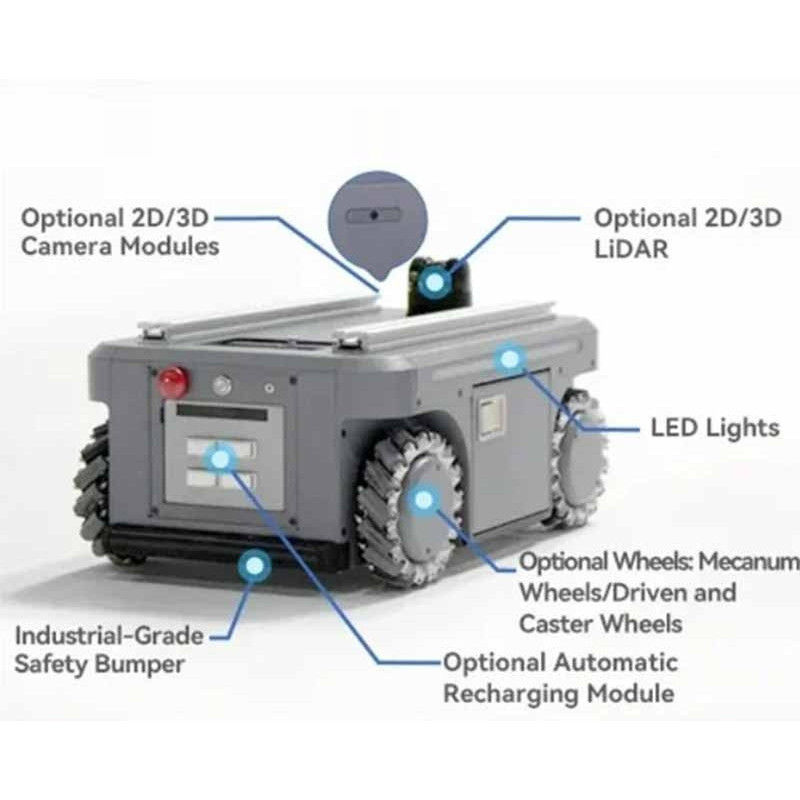


LiDAR autonomous mobile robot
Available to order – delivery in approx. 35 days
 Privacy Policy
 Delivery policy
 Return policy
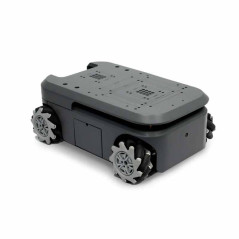
myAGV Pro 3D LiDAR autonomous mobile robot, by Elephant Robotics, is an omnidirectional AGV/AMR platform.
It carries up to 50 kg and moves at up to 1.5 m/s.
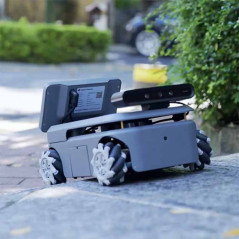
The Visual Navigation version features a 360° 3D LiDAR, an Orbbec Gemini 2 3D depth camera and an NVIDIA Jetson Orin Nano computer.
It comes with Ubuntu 22.04 and ROS2 Humble preinstalled.
It is a complete platform for teaching and research in mobile robotics, artificial intelligence and embodied AI.
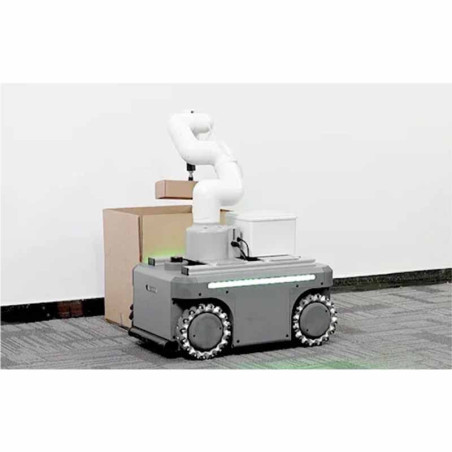
Robotic arms such as the myCobot 320, myCobot Pro 630, myArm M750 or Mercury A1 can be mounted on it, giving you a compound robot that moves and manipulates objects.
For STEAM education, AI and robotics
Students and researchers work with the same technologies used in industry: SLAM 2D/3D mapping and navigation, Nav2, computer vision, 3D point clouds and sensor fusion.
It can be used to teach programming in Python, ROS2, simulation in Gazebo and RViz, reinforcement learning and imitation learning.
The robot covers the whole journey, from the first lessons in autonomous navigation to university research projects and collecting datasets for AI models.
Key advantages and technical performance 3D LiDAR autonomous mobile robot
Complete 3D perception – the 360° 3D LiDAR and the Orbbec Gemini 2 depth camera provide 3D maps, obstacle detection at different heights and object recognition.
AI computing power – the NVIDIA Jetson Orin Nano 8 GB runs computer vision models and SLAM algorithms directly on the robot.
50 kg payload – it can carry robotic arms, additional sensors or goods, making it ideal for compound robots.
Omnidirectional mobility – omnidirectional steering system, 0 m turning radius (in-place rotation), swing-arm independent suspension and climbs ramps of up to 10°.
ROS2 Humble and 3D SLAM – comes with Ubuntu 22.04 LTS preinstalled and supports Gmapping, Cartographer and RTAB-Map, Nav2, RViz and Gazebo.
Open development – Python API with code examples, RS232 serial protocol for microcontrollers, 6 programmable digital inputs and 6 digital outputs.
Safe LiFePO4 battery – the 24 V / 20 Ah battery offers excellent thermal stability, long service life and 5–6 hours of runtime.
Quick-release battery – the battery can be swapped in seconds, so the robot can operate almost continuously.
Automatic charging – when the battery runs low, the robot returns to its charging station on its own.
Easy start-up – the visual interface starts the robot with one click, and the plug-and-play wireless controller allows immediate manual control.
Application areas and use cases 3D LiDAR autonomous mobile robot
STEAM education and universities – mobile robotics labs, ROS2 courses, autonomous navigation and computer vision.
Embodied AI research – data collection and policy validation for reinforcement learning and imitation learning.
Logistics and sorting – together with the myCobot 320 and a vacuum pump, it forms a training environment for sorting and loading parcels.
Home service simulation – with the myArm M750 it can simulate tasks such as laundry handling, generating multimodal (visual and tactile) datasets.
Smart office – with the myCobot Pro 630, a force-controlled gripper and the vision system, it can reproduce the door-opening task developed at CMU.
Warehousing and intralogistics – enables prototyping of autonomous transport workflows in warehouses and production halls.
Patrol and monitoring – can be used for indoor security patrols, with 3D maps and obstacle detection.
Technical specifications 3D LiDAR autonomous mobile robot
Dimensions: 530 × 360 × 245 mm
Weight: 40 kg
Maximum payload: 50 kg
Drive mode: omnidirectional steering system
Maximum speed (at full load): 1.5 m/s
Minimum turning radius: 0 m (in-place rotation)
Maximum slope: 10°
Suspension: swing-arm independent
Computer: NVIDIA Jetson Orin Nano 8 GB
Operating system: Ubuntu 22.04 LTS, ROS2 Humble
Navigation: SLAM 2D/3D (Gmapping, Cartographer, RTAB-Map), Nav2
Simulation: RViz, Gazebo
3D LiDAR: 360°, 3D point cloud, built-in IMU
3D camera: Orbbec Gemini 2, active structured-light stereo, depth 0.15–10 m, 1280 × 800 at 30 fps, RGB 1920 × 1080 at 30 fps, 6-axis IMU
Communication: RS232
Battery: LiFePO4 24 V / 20 Ah, quick-release
Runtime: 5–6 hours (no load, at 1 m/s)
Charging time: 5–6 hours
Operating environment: indoor
Protection rating: IP22
Operating temperature: -10…40 °C
External interfaces: DC4017 charging port, XT60 24 V / 5 A (max. 120 W, for robotic arms), XT30 12 V / 5 A, USB-C serial, Gigabit Ethernet RJ45, HDMI, 6 digital inputs, 6 digital outputs, 2 × USB 3.0
Package contents and accessories
1 × myAGV Pro mobile robot (omnidirectional chassis)
1 × 3D LiDAR
1 × Orbbec Gemini 2 3D depth camera
1 × NVIDIA Jetson Orin Nano 8 GB computer
1 × automatic charging station
1 × wireless controller
1 × battery charger (25.55 V / 2.8 A)
Optional accessories
myCobot 320 robotic arm – for mobile manipulation and sorting
myCobot Pro 630 robotic arm – for tasks requiring a higher payload
myArm M750 robotic arm – for home service simulation and data collection
Mercury A1 robotic arm – for advanced embodied AI research
Spare LiFePO4 24 V / 20 Ah battery – for continuous operation
Elephant Robotics grippers and vacuum pumps – for grasping objects
Mecanum wheels – alternative chassis option
Frequently asked questions
What is myAGV Pro?
It is an omnidirectional autonomous mobile robot by Elephant Robotics. It has a 50 kg payload, runs ROS2 Humble and is designed for education, AI research and logistics.
What does the Visual Navigation version add?
It adds a 3D LiDAR, the Orbbec Gemini 2 depth camera, the Jetson Orin Nano computer and the automatic charging station. This allows the robot to perform 3D mapping, autonomous navigation and object recognition.
Can I mount a robotic arm on myAGV Pro?
Yes. The robot has a 24 V / 120 W XT60 power port and is compatible with the myCobot 320, myCobot Pro 630, myArm M750 and Mercury A1.
Specific References
LiDAR autonomous mobile robot
Available to order – delivery in approx. 35 days