


- New



 Privacy Policy
 Delivery policy
 Return policy
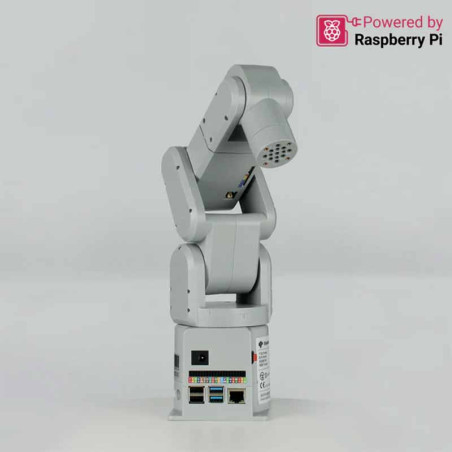
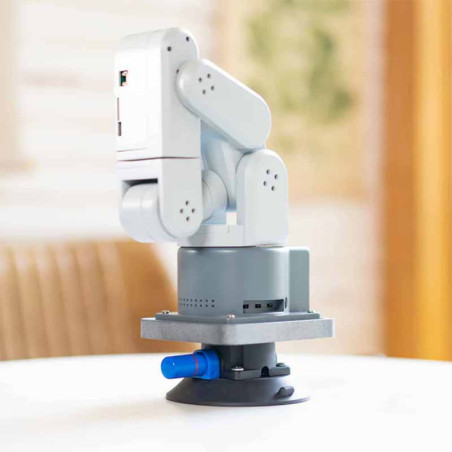
mechArm 270 Pi is a small-scale, extremely compact and portable industrial-type articulated robotic arm equipped with 6 degrees of freedom (6 DOF). Unlike other models in its class, mechArm features a centrosymmetric structure (each joint has two physical mounting/support points), providing enhanced reliability and structural rigidity.
This version integrates a Raspberry Pi 4 Model B (4B) single-board computer directly as the central control unit, allowing the user to run complex applications directly on the robot by connecting an HDMI monitor and peripherals, without relying on an external PC. The system runs Debian/Ubuntu-based environments and is fully compatible with ROS (Robot Operating System) and MoveIt.
It is a versatile piece of equipment, ideal for maker communities, designers, universities, and research laboratories implementing applications for visual sorting, smart tracking, object moving, or voice command interaction.
General robotic arm technical specifications
Number of axes (Degrees of Freedom): 6 DOF
Maximum working radius (Working range): 270 mm
Maximum payload: 250 g
Net arm weight: 1 kg (approximately 1.3 kg with some basic accessories installed)
Repeatability accuracy (Repeatability): +/- 0.5 mm to +/- 1 mm (depending on the axis and payload)
Maximum movement speed: Up to 120 degrees / second per joint
Power interface: DC 8V - 12V / 5A (recommended 12V / 5A)
Motor / servo type: High-precision servo motors with magnetic encoders
Structure type: Centrosymmetric design, optimized for reliability and balanced movement
Base mounting method: Interfaces compatible with LEGO-style connectors + holes for suction cup or G-Shape clamp mounting
Main controller specifications (Raspberry Pi 4 Model B)
Main processor (CPU): Broadcom BCM2711, Quad-core Cortex-A72 (ARM v8) 64-bit, at 1.5 GHz frequency
Wireless connectivity: Dual-band Wi-Fi (2.4 GHz and 5.0 GHz) IEEE 802.11ac, Bluetooth 5.0 / BLE
Network interface: 1x Gigabit Ethernet port (RJ45)
USB interfaces: 2x USB 3.0 ports, 2x USB 2.0 ports
Video interfaces: 2x Micro HDMI ports (supports resolutions up to 4K at 60fps)
Hardware expansion: Standard 40-pin GPIO header available for external sensors
End effector IO and interface specifications
Available pins at the end of the arm: 5 Digital Input/Output (DIO) + dedicated 3-pin port
Accessory compatibility: Mechanical flange pre-configured for installing adaptive mini-grippers, vacuum pumps, lightweight laser engraving modules, or camera mounts.
Software development and ecosystem
Compatible operating systems on the controller: Ubuntu / Debian (optimized for robotics environments)
Programming interfaces and libraries: Python, C++, ROS, MoveIt
Visual programming environment: myBlockly (block-based graphical programming, excellent for beginners and STEM education)
Included software utilities: myStudio (for firmware updates and joint calibration)
Pre-configured applications and optional kits: Support for visual sorting (AI Kit with color/shape recognition via OpenCV), strategy games (Gomoku), drawing, writing, and advanced kinematic simulations.
Specific References
No customer reviews for the moment.