- New


 Privacy Policy
 Delivery policy
 Return policy
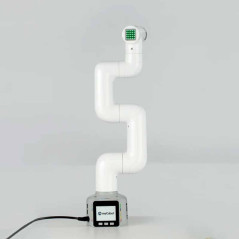
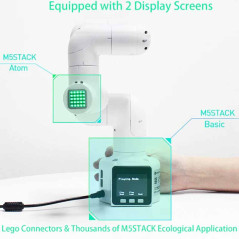
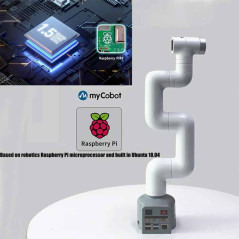
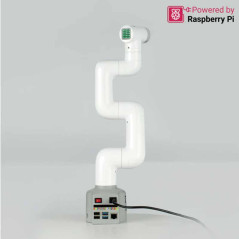
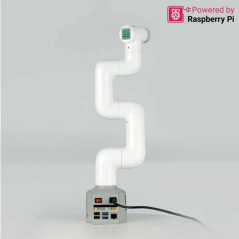
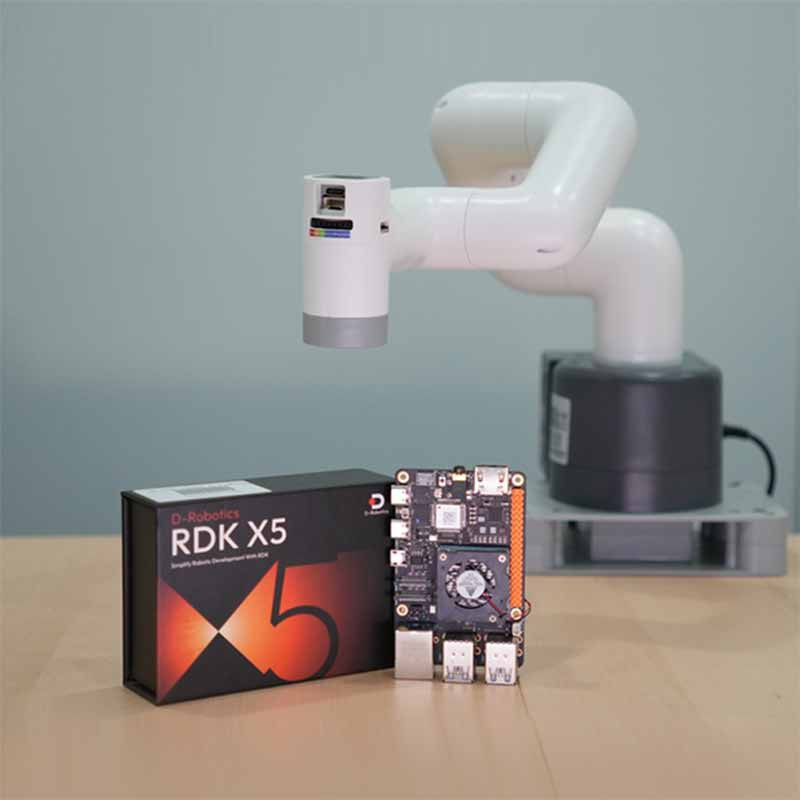
myCobot 280 RDK X5 is an ultra-compact, lightweight, and portable collaborative robotic arm equipped with 6 degrees of freedom (6 DOF). This version integrates the D-Robotics RDK X5 development board and runs the RDK OS operating system (built upon the TogetheROS.Bot middleware and optimized for ROS 2 Humble).
The arm delivers an outstanding computing power of up to 10 TOPS, being specifically engineered for advanced artificial intelligence (AI) applications, natural language interaction (LLMs), and computer vision. It supports local deployment of complex models such as Deepseek, LLaMA, Qwen2, YOLOv8, and open-source algorithms (Transformer, RWKV).
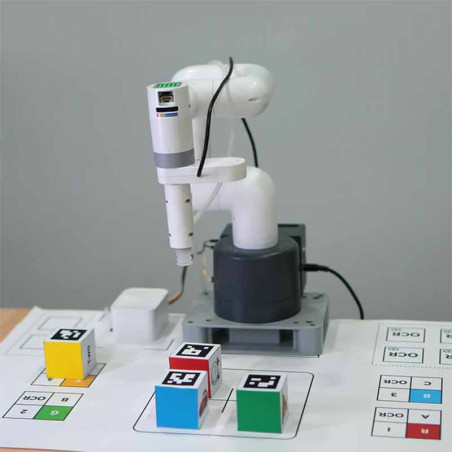
It is ideal for robotics laboratories, universities, research, and developers exploring gestural interaction, optical character recognition (OCR), waste sorting, or ArUco code-based palletizing.
General robotic arm technical specifications
Number of axes (Degrees of Freedom): 6 DOF
Maximum working radius (Working range): 280 mm
Arm length (Span): 350 mm
Maximum payload: 250 g
Net arm weight: 860 g
Repeatability accuracy: +/- 0.5 mm
Lifespan estimation: 500 hours
Power interface: DC 12V / 5A
Structure material: Industrial nylon
Encoder type: 12-bit magnetic encoder
Joint movement range: J1 to J6 between -165 degrees and +165 degrees (J6 supports -179 degrees to +179 degrees)
Supported motion types: Free movement, joint movement, Cartesian coordinate movement, trajectory recording
Base mounting method: LEGO-style connectors + screw holes
Main controller specifications (D-Robotics RDK X5)
Main processor (CPU): Octa-core (8x) Cortex-A55 with 1.5 GHz frequency
Graphics processor (GPU): 32 GFLOPS
Neural processing unit (BPU): 10 TOPS
RAM memory: 8GB LPDDR4
Compatible operating system: RDK OS (optimized Ubuntu 22.04 / ROS 2 Humble)
USB interfaces: 4x USB 3.0 Host (Type A)
Network interface: 1x Gigabit Ethernet port (RJ45) with PoE support
Wireless connectivity: Wi-Fi 6 and Bluetooth 5.4
Video interface: 1x HDMI port (supports up to 1080p at 60fps)
Audio interface: 3.5mm Jack (input/output)
Gyroscope data: Supports data reading
GPIO interfaces (RDK X5): Configurable Input/Output pins (supports UART, PWM, I2C, SPI, CAN FD)
Co-processor specifications (Location: Arm extremity / ATOM Matrix)
Co-processor model: ESP32 x1
Co-processor performance: Dual-core 240MHz, 600 DMIPS, 520KB SRAM
Co-processor Flash memory: 4MB
Co-processor connectivity: Wi-Fi / Bluetooth dual-mode
Dedicated co-processor GPIO pins: G19, G21, G22, G23, G25, G33
Software development and ecosystem
Operating system compatibility for control: Windows, Linux, macOS
Development frameworks: ROS 2, Python, myBlockly, myStudio
Supported communication protocols: Serial (serial interface via Micro USB for debugging), TCP/IP, MODBUS
Standard integrated visual algorithms: Color recognition, object recognition (YOLOv8), waste detection, ArUco code palletizing, OCR text recognition, Stag Code recognition, gestural interaction.
Specific References
No customer reviews for the moment.