
- New


 Privacy Policy
 Delivery policy
 Return policy
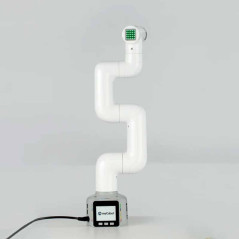
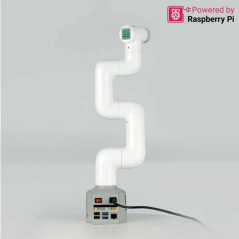
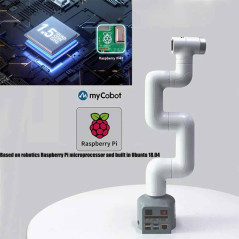
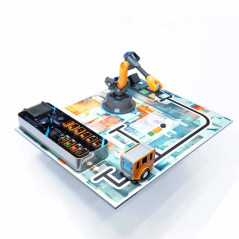
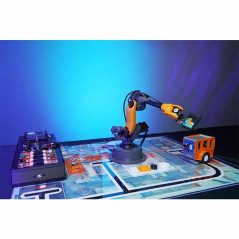
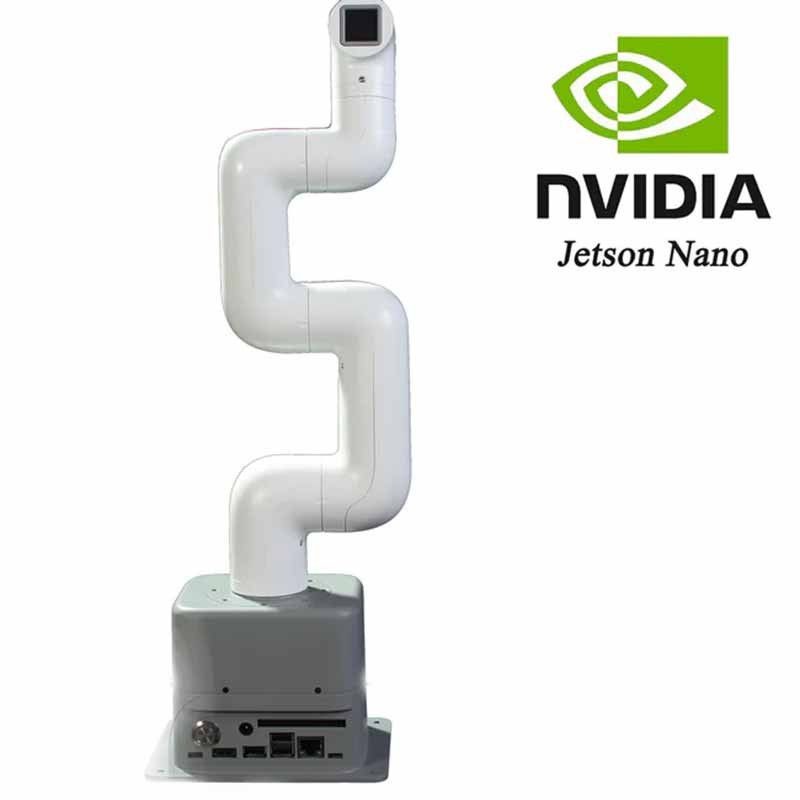
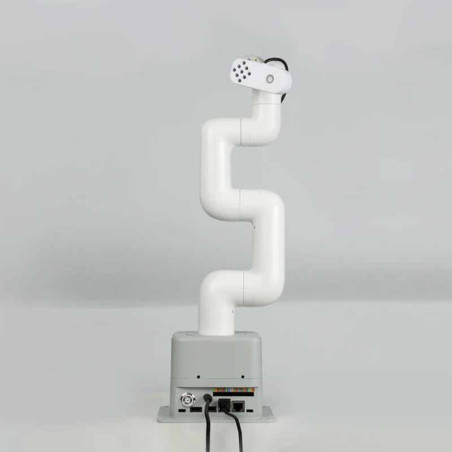
Elephant Robotics myCobot 280 Jetson Nano - 6 DOF Collaborative Robot represents one of the most compact and versatile 6-degree-of-freedom (6 DOF) collaborative robotic arms in the world, developed by Elephant Robotics in official collaboration with NVIDIA.
Designed specifically as an integrated learning and research platform for artificial intelligence (AI), computer vision, and advanced robotics, the myCobot 280 Jetson Nano utilizes a powerful dual-core architecture based on the NVIDIA Jetson Nano processing unit (Quad-Core ARM A57 CPU, 128-core NVIDIA Maxwell GPU, 2 GB LPDDR4) alongside the M5Stack ATOM auxiliary microcontroller (dual-core ESP32).
The device natively runs the Ubuntu Mate 20.04 operating system, eliminating the need to connect to an external PC. The myCobot 280 Jetson Nano can be used as an independent micro-computer by simply connecting an HDMI monitor, keyboard, and mouse.
The system comes pre-configured with major development environments such as Python, ROS1, ROS2, and myBlockly (visual block-based programming), facilitating a rapid transition from theoretical concepts to practical applications.
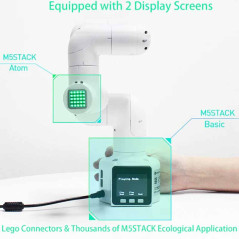
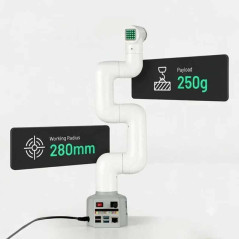
With a self-weight of only 1030 g, a working radius of 280 mm, and a payload capacity of 250 g, the myCobot 280 Jetson Nano integrates 6 high-performance servomotors and a 5x5 RGB LED matrix on the robot's head.
The base and end-effector flange are equipped with Lego-compatible mounting interfaces and M4/M2.5 threads, offering maximum flexibility for integrating various accessories and sensors.
Key advantages and technical performance
Dual-Core Architecture and High-Performance AI: Equipped with the NVIDIA Jetson Nano development board and an ESP32 auxiliary processor (M5Stack ATOM), the myCobot 280 Jetson Nano offers advanced capabilities for graphic processing, vision algorithms, and real-time cinematic control.
Integrated Operating System (Autonomous Operation): Running Ubuntu Mate 20.04 pre-installed on a 64 GB TF card, the myCobot 280 Jetson Nano does not require a host computer; it connects directly to a monitor via HDMI and to peripherals through USB 3.0 / 2.0 ports.
Extensive Software Compatibility: Native support for Python (pymycobot library), ROS1 (Noetic), ROS2 (Foxy/Humble), RViz and MoveIt! simulation environments, as well as the myBlockly drag-and-drop visual programming environment for the myCobot 280 Jetson Nano
Precise Motion Control: 6 axes of rotation with precision servomotors
Rich I/O Interfaces and Connectivity: 40-pin GPIO header (BCM mode), network connectivity via a Gigabit RJ45 port, a Grove interface, and Type-C ports for electronic expansions and external sensors.
Compact, Modular, and Safe Design: Weighing only 1.03 kg, it features integrated algorithmic self-protection collision functions and the possibility of mounting on suction cup bases or G-Stand clamps.
Application domains and usage scenarios
STEM and University Education: The ideal platform for teaching robotics, forward and inverse kinematics, applied physics, and programming logic using the myCobot 280 Jetson Nano from beginner levels (Blockly) to advanced levels (Python, C++).
AI / Computer Vision Research and Innovation: Development and testing of object recognition, visual tracking, and automatic sorting algorithms in combination with USB cameras connected directly to the myCobot 280 Jetson Nano and OpenCV libraries.
Prototyping and Mobile Robotics Laboratories: Integration on mobile chassis for complex SLAM mapping, autonomous navigation, and collaborative manipulation applications with the help of the myCobot 280 Jetson Nano.
Commercial Demonstrations and Exhibitions: Dynamic presentations in technology booths, automation of light repetitive tasks (pick and place, writing/drawing with a pen holder).
Technical specifications
Degrees of Freedom (DOF): 6 axes
Payload: 250 g
Working Radius: 280 mm
Wingspan: 350 mm
Repeatability Accuracy: ±0.5 mm
Net Weight: 1030 g
Supply Voltage: 8.4V – 14V DC (Recommended power adapter 12V, 5A)
Operating Temperature: -5°C to 45°C
Main Control Processor: NVIDIA Jetson Nano (Quad-core ARM A57 @ 1.43 GHz, 128-core Maxwell GPU, 2 GB 64-bit LPDDR4)
Co-controller: ESP32 (Dual-core 240 MHz, 520 KB SRAM, Wi-Fi/Bluetooth)
Operating System: Ubuntu Mate 20.04 (installed on a 64GB TF card)
Base Interfaces
1x HDMI Type A
1x Gigabit RJ45 Network Port
1x USB 3.0, 2x USB 2.0
1x Micro USB, 1x Type-C
40-pin GPIO Header (DuPont 2.54mm)
DC Power Jack (6.5mm / 2.0mm) and Power Button with LED
Head / End Effector Interfaces
Servomotor Interface (for dedicated grippers)
Grove Port (G26, G32, 5V, GND)
Type-C Port
5x5 RGB LED Matrix (controlled via ATOM / GPIO27) + Button (GPIO39)
Joint Movement Range
J1: -168° ~ +168°
J2: -140° ~ +140°
J3: -150° ~ +150°
J4: -150° ~ +150°
J5: -155° ~ +160°
J6: -180° ~ +180°
Package Contents and Accessories
1 x myCobot 280 Jetson Nano Robotic Arm (with pre-installed 64GB TF card)
1 x Mains Power Adapter (DC 12V 5A) and power cable
1 x HDMI Cable
1 x USB to Type-C Cable
1 x Video Camera Mounting Flange
1 x Set of pins and LEGO-type connection parts
2 x DuPont Cables
1 x Allen wrench
1 x Brochure and quick user guide
Compatible Accessories
Fixing Bases: Flat Base with suction cups (Flat Base), Desk edge clamping mount (G-Stand).
End-Effectors: Adaptive Gripper, Parallel Gripper, Flexible Gripper, Dexterous Hand.
Suction Systems: Vertical Suction Pump, Double-head suction pump, Integrated suction pump.
Additional Modules: USB Camera Module, Pen holder, Mobile phone holder, Cylindrical / bamboo flange.
Specific References
No customer reviews for the moment.